publications

* Equal contribution

2026

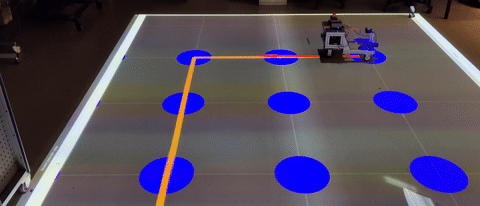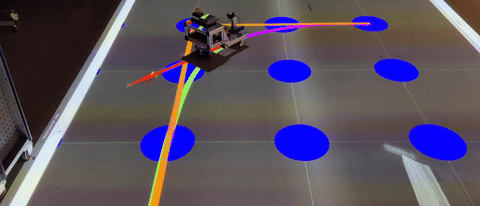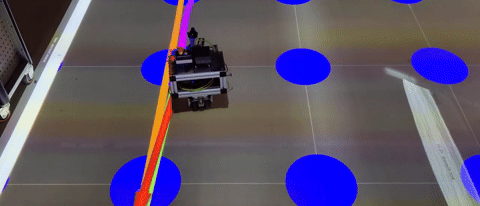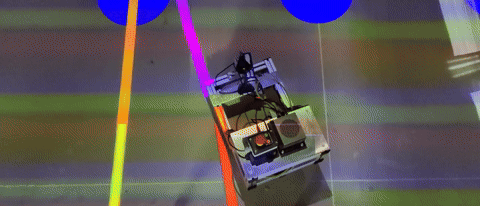
  1. ICRA26.gif
    Fast Motion Planning for Non-Holonomic Mobile Robots via a Rectangular Corridor Representation of Structured Environments
    Alejandro Gonzalez-Garcia, Sebastiaan Wyns, Sonia De Santis, and 2 more authors
    In 2026 IEEE International Conference on Robotics and Automation (ICRA), 2026
  2. GainOpt.gif
    Optimizing unmanned surface vehicle control: A data-enabled learning approach
    Xiaocong Li*, Alejandro Gonzalez-Garcia*, and Herman Castañeda
    Control Engineering Practice, 2026
  3. crane.png
    Safe and Time-Minimal Control for Overhead Cranes based on MPC and Control Barrier Functions
    Felix Ebert, Alvaro Florez, Alejandro Gonzalez-Garcia, and 2 more authors
    In 2026 IEEE Conference on Control Technology and Applications (CCTA), 2026
  4. pip.gif
    Safe Polytope-in-Polytope Motion Planning and Control with Control Barrier Functions
    Alejandro Gonzalez-Garcia*, Dries Dirckx*, Jan Swevers, and 1 more author
    arXiv preprint arXiv:2606.09719, 2026
  5. constant_rate.png
    Constant-Rate Convergence for an Adaptive Sliding Mode Controller Using a Fixed-time Disturbance Observer
    Alejandro Gonzalez-Garcia, Armando Miranda-Moya, and Herman Castañeda
    International Journal of Robust and Nonlinear Control, 2026
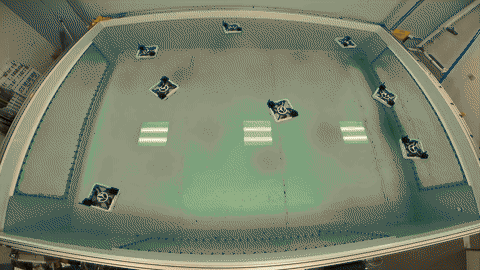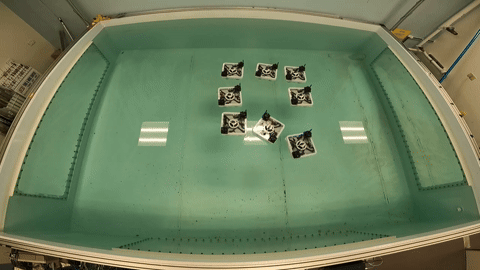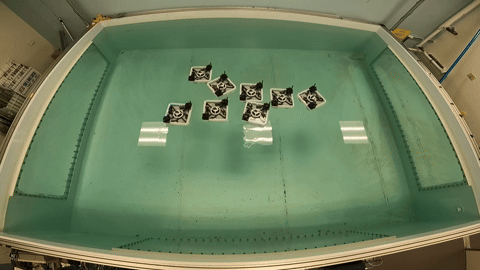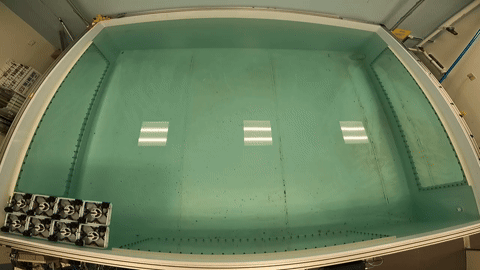
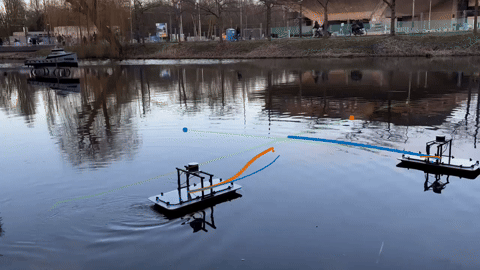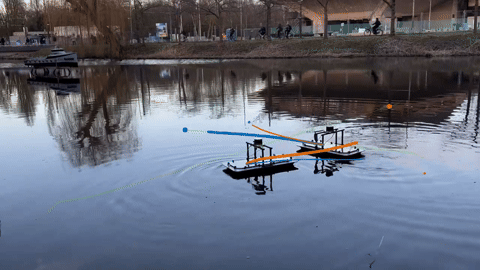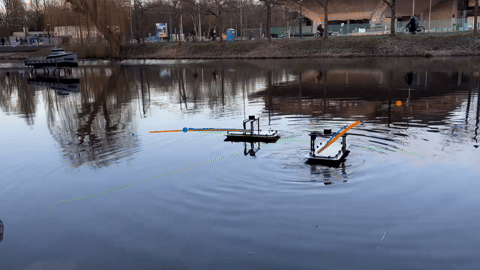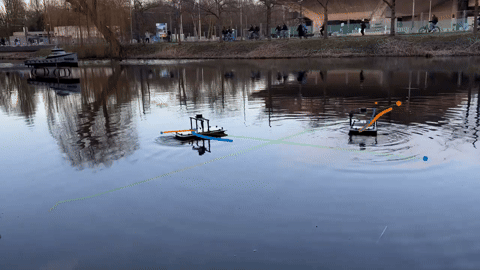
  6. Self-Reconfigurable Boats.gif
    Self-Reconfiguring Modular Robotic Boats
    Wei Wang*, Niklas Hagemann*, Alejandro Gonzalez-Garcia*, and 2 more authors
    Nature Communications, 2026
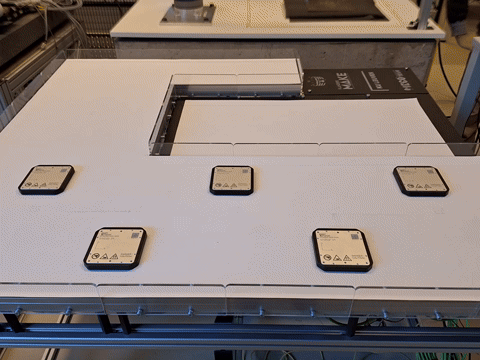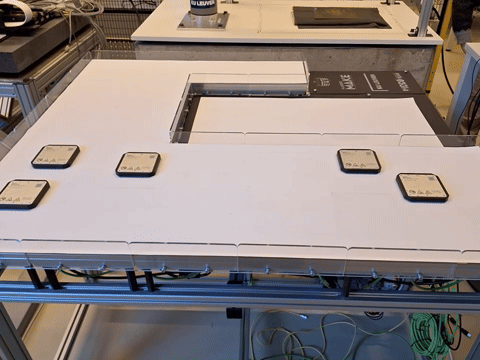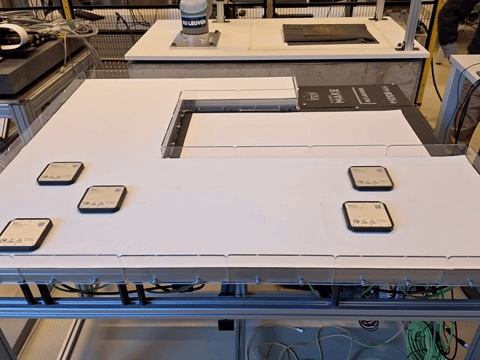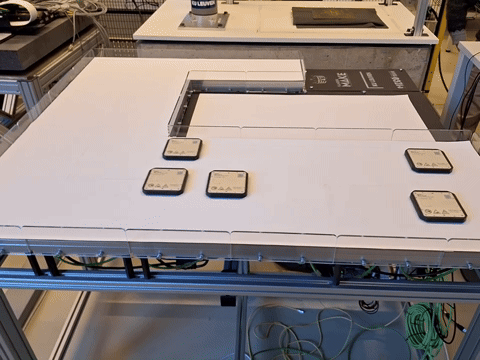
  7. MagLevADMM-CBF.gif
    Multi-Agent Motion Planning on Industrial Magnetic Levitation Platforms: A Hybrid ADMM-HOCBF approach
    Bavo Tistaert, Stan Servaes, Alejandro Gonzalez-Garcia, and 4 more authors
    European Journal of Control, 2026
    Special Issue on ECC 2026
  8. admm-cbf.gif
    Distributed Motion Planning with Safety Guarantees for Self-Reconfiguring Robotic Boats
    Alejandro Gonzalez-Garcia, Wei Wang, Wei Xiao, and 4 more authors
    arXiv preprint arXiv:2607.20352, 2026
  9. AITSMC.gif
    Adaptive Unmanned Surface Vehicle Control Under Perturbations with a Tunable Settling Time
    Alejandro Gonzalez-Garcia and Herman Castañeda
    IEEE/ASME Transactions on Mechatronics, 2026
  10. interaction-mppi.gif
    Interaction-Aware Sampling-Based Motion Planning for Autonomous Surface Vessels in Urban Waterways
    Elia Trevisan, Alejandro Gonzalez-Garcia, Jan Swevers, and 1 more author
    arXiv preprint arXiv:2610.41676, 2026

2025

  1. Safe Motion Planning for ASVs in Narrow Environments.gif
    Safe Motion Planning and Control Using Predictive and Adaptive Barrier Methods for Autonomous Surface Vessels
    Alejandro Gonzalez-Garcia, Wei Xiao, Wei Wang, and 5 more authors
    In 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
  2. Smooth controls AGV.gif
    Smooth Control Strategies for Path-Following on Computationally Constrained Mobile Robots with Discontinuous Localization
    Yannick Claes, Lucas Tielens, Sonia De Santis, and 3 more authors
    In 2025 European Control Conference (ECC), 2025

2024

  1. Safe Robust Control ASVs.gif
    Robust Model Predictive Control with Control Barrier Functions for Autonomous Surface Vessels
    Wei Wang*, Wei Xiao*, Alejandro Gonzalez-Garcia*, and 3 more authors
    In 2024 IEEE International Conference on Robotics and Automation (ICRA), 2024
  2. Unmanned surface vehicle robust tracking control using an adaptive super-twisting controller
    Alejandro Gonzalez-Garcia, Herman Castañeda, and Jesús De León-Morales
    Control Engineering Practice, 2024
  3. Adaptive sliding mode control with nonlinear MPC-based obstacle avoidance using LiDAR for an autonomous surface vehicle under disturbances
    Ivana Collado-Gonzalez*, Alejandro Gonzalez-Garcia*, Rodolfo Cuan-Urquizo, and 3 more authors
    Ocean Engineering, 2024

2023

  1. Novel adaptive law for super-twisting controller: USV tracking control under disturbances
    Enrique Alvaro-Mendoza, Alejandro Gonzalez-Garcia, Herman Castañeda, and 1 more author
    Isa Transactions, 2023
  2. DRLICRA23.gif
    Deep Reinforcement Learning Based Tracking Control of an Autonomous Surface Vessel in Natural Waters
    Wei Wang, Xiaojing Cao, Alejandro Gonzalez-Garcia, and 5 more authors
    In 2023 IEEE International Conference on Robotics and Automation (ICRA), 2023

2022

  1. usv.png
    Adaptive integral terminal super-twisting with finite-time convergence for an unmanned surface vehicle under disturbances
    Alejandro Gonzalez-Garcia and Herman Castañeda
    International Journal of Robust and Nonlinear Control, 2022
  2. sigma_circle.png
    Finite-time control for an Unmanned Surface Vehicle based on adaptive sliding mode strategy
    Jonathan Rodriguez, Herman Castañeda, Alejandro Gonzalez-Garcia, and 1 more author
    Ocean Engineering, 2022
  3. COLAV.gif
    Path-following and LiDAR-based obstacle avoidance via NMPC for an autonomous surface vehicle
    Alejandro Gonzalez-Garcia*, Ivana Collado-Gonzalez*, Rodolfo Cuan-Urquizo, and 3 more authors
    Ocean Engineering, 2022
  4. RobustUUV.gif
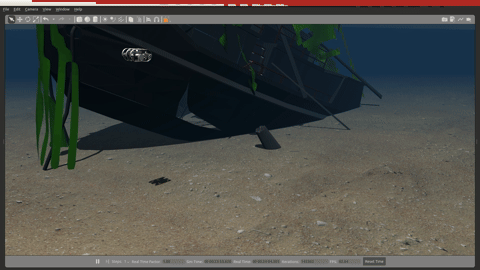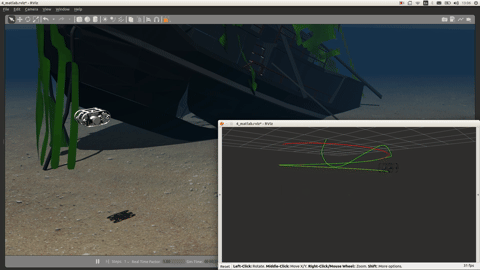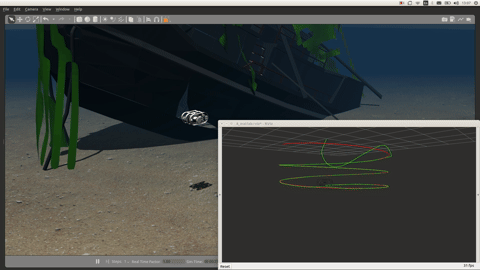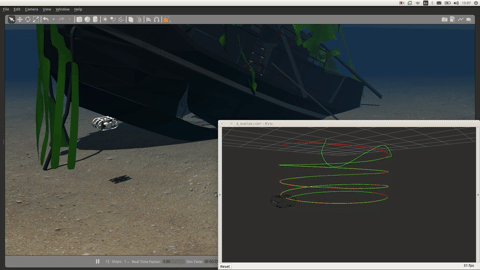
    Adaptive Non-Singular Terminal Sliding Mode Tracking Control of an UUV Against Disturbances
    V Sebastian Martinez-Perez, Andres E Sanchez-Calvo, Alejandro Gonzalez-Garcia, and 1 more author
    IFAC-PapersOnLine, 2022
  5. Adaptive Integral Terminal Sliding Mode Guidance and Control for a UUV Under Perturbations
    Andres E Sanchez-Calvo, V Sebastian Martinez-Perez, Alejandro Gonzalez-Garcia, and 1 more author
    In 2022 Congreso Nacional de Control Automático, 2022
2021

  1. joe2021.gif
    Guidance and Control Based on Adaptive Sliding Mode Strategy for a USV Subject to Uncertainties
    Alejandro Gonzalez-Garcia and Herman Castañeda
    IEEE Journal of Oceanic Engineering, 2021
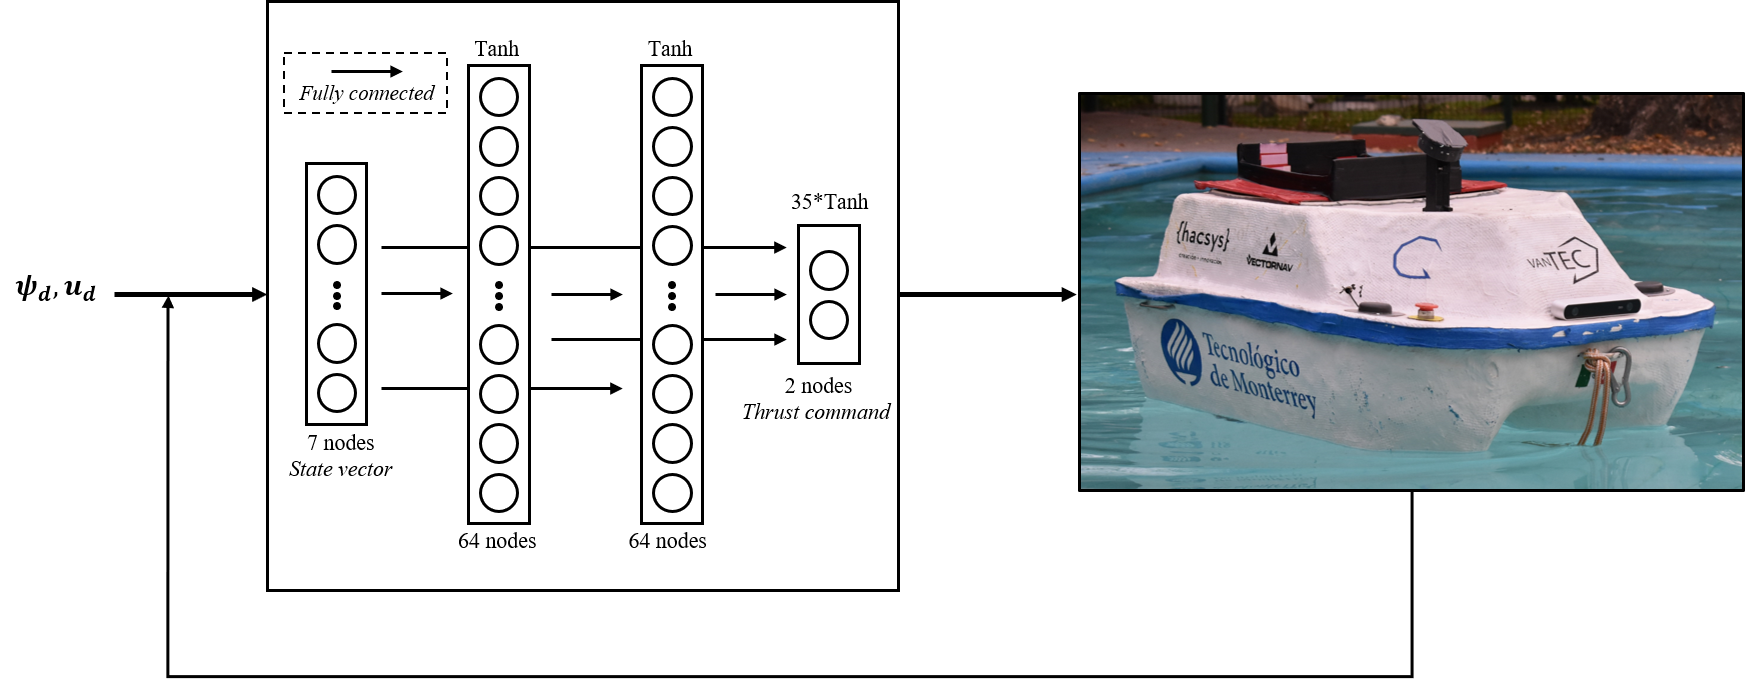
  2. NN.png
    Adaptive dynamic programming and deep reinforcement learning for the control of an unmanned surface vehicle: Experimental results
    Alejandro Gonzalez-Garcia, David Barragan-Alcantar, Ivana Collado-Gonzalez, and 1 more author
    Control Engineering Practice, 2021
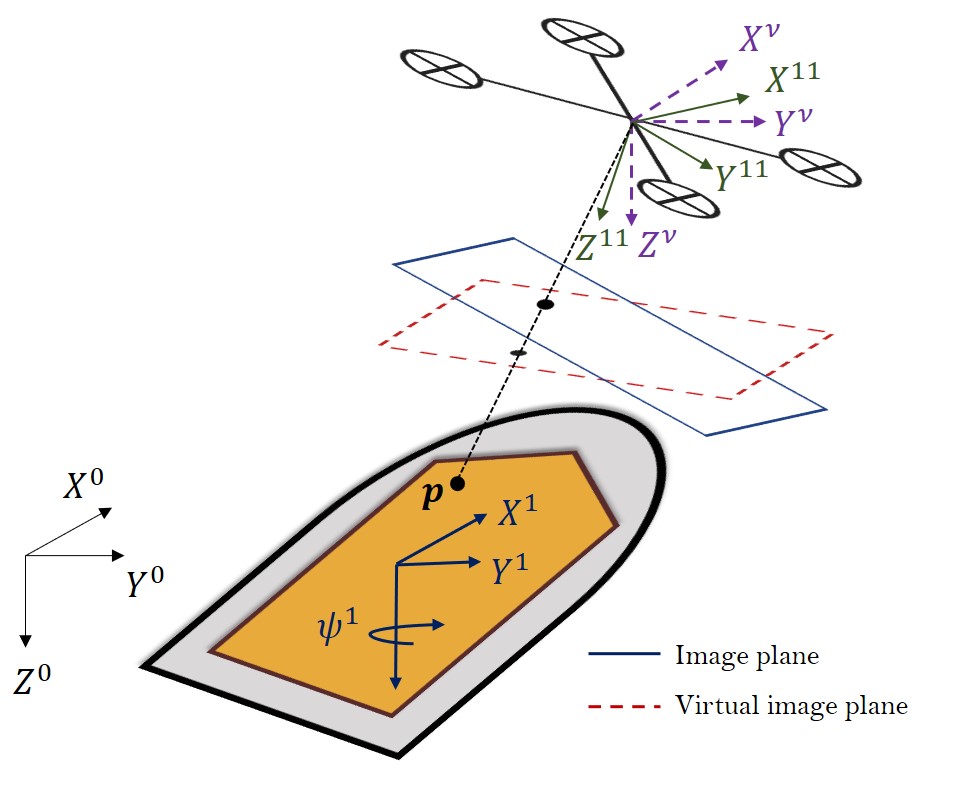
  3. UAV_USV.jpg
    Robust Visual Tracking Control Based on Adaptive Sliding Mode Strategy: Quadrotor UAV-Catamaran USV Heterogeneous System
    Alejandro Gonzalez-Garcia, Armando Miranda-Moya, and Herman Castañeda
    In 2021 International Conference on Unmanned Aircraft Systems (ICUAS), 2021
  4. Adaptive Integral Terminal Sliding Mode Control for an Unmanned Surface Vehicle Against External Disturbances
    Alejandro Gonzalez-Garcia and Herman Castañeda
    IFAC-PapersOnLine, 2021
  5. A Real-Time NMPC Guidance Law and Robust Control for an Autonomous Surface Vehicle
    Ivana Collado-Gonzalez, Alejandro Gonzalez-Garcia, Carlos Sotelo, and 2 more authors
    IFAC-PapersOnLine, 2021

2020

  1. USV Path-Following Control Based On Deep Reinforcement Learning and Adaptive Control
    A Gonzalez-Garcia, H Castañeda, and L Garrido
    In Global Oceans 2020: Singapore – U.S. Gulf Coast, 2020