Safe Motion Planning and Control

Optimization-based planning and control with safety guarantees.

Different systems operate in environments where safety-critical solutions are required. That is the case for instance of ASVs operating in inland waterways, or AMRs in unstructured spaces, as they must deal with narrow environments where maneuverability is essential and complex. Model predictive control (MPC) has been widely used for motion planning and control, as it handles constraints while predicting the system’s behavior. However, safety is typically enforced through distance constraints that only act once the predicted trajectory approaches an obstacle, and the complexity may explode with the number of obstacles or complex constraints. Control barrier functions (CBFs) guarantee safety by keeping the system within a safe set, but on their own they lack prediction. This project explores different ways of combining MPC and CBFs for safe motion planning and control, either using CBFs as a safety filter on the MPC solution, or as discrete-time CBF constraints within the MPC.

2026

  1. crane.png
    Safe and Time-Minimal Control for Overhead Cranes based on MPC and Control Barrier Functions
    Felix Ebert, Alvaro Florez, Alejandro Gonzalez-Garcia, and 2 more authors
    In 2026 IEEE Conference on Control Technology and Applications (CCTA), 2026
  2. pip.gif
    Safe Polytope-in-Polytope Motion Planning and Control with Control Barrier Functions
    Alejandro Gonzalez-Garcia*, Dries Dirckx*, Jan Swevers, and 1 more author
    arXiv preprint arXiv:2606.09719, 2026
  3. MagLevADMM-CBF.gif
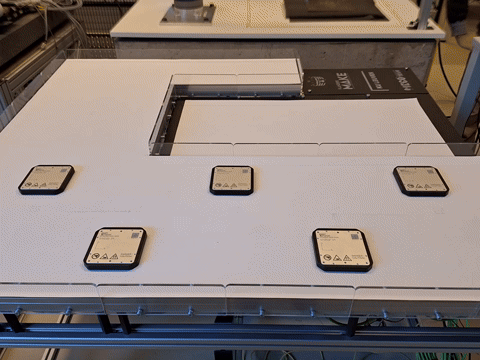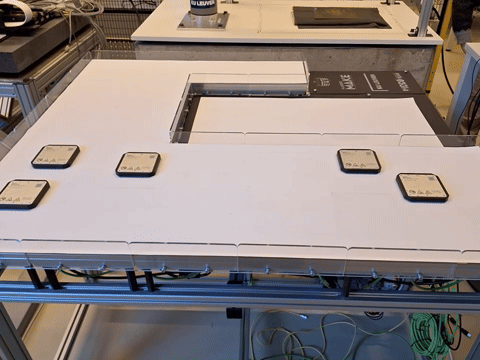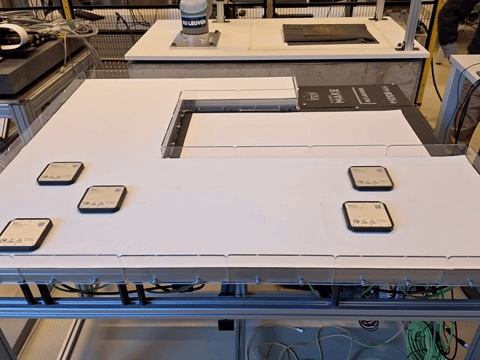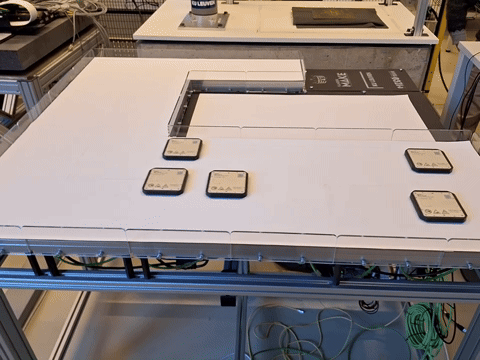
    Multi-Agent Motion Planning on Industrial Magnetic Levitation Platforms: A Hybrid ADMM-HOCBF approach
    Bavo Tistaert, Stan Servaes, Alejandro Gonzalez-Garcia, and 4 more authors
    European Journal of Control, 2026
    Special Issue on ECC 2026
  4. admm-cbf.gif
    Distributed Motion Planning with Safety Guarantees for Self-Reconfiguring Robotic Boats
    Alejandro Gonzalez-Garcia, Wei Wang, Wei Xiao, and 4 more authors
    arXiv preprint arXiv:2607.20352, 2026

2025

  1. Safe Motion Planning for ASVs in Narrow Environments.gif
    Safe Motion Planning and Control Using Predictive and Adaptive Barrier Methods for Autonomous Surface Vessels
    Alejandro Gonzalez-Garcia, Wei Xiao, Wei Wang, and 5 more authors
    In 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025

2024

  1. Safe Robust Control ASVs.gif
    Robust Model Predictive Control with Control Barrier Functions for Autonomous Surface Vessels
    Wei Wang*, Wei Xiao*, Alejandro Gonzalez-Garcia*, and 3 more authors
    In 2024 IEEE International Conference on Robotics and Automation (ICRA), 2024