Robust Control of Underwater Vehicles
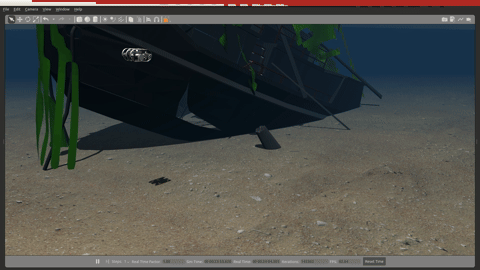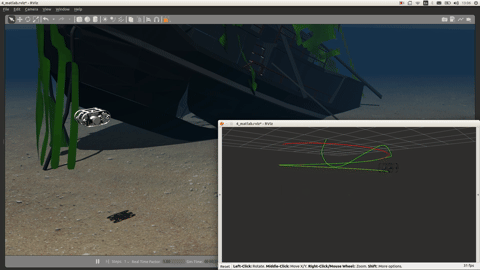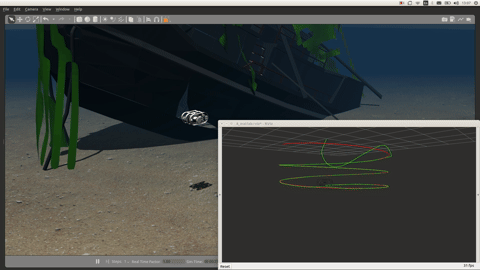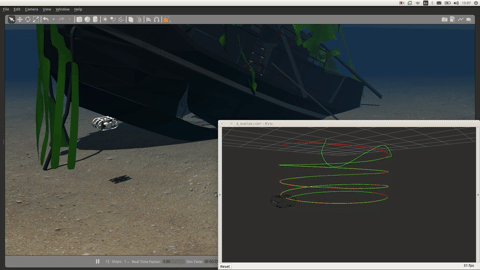
Adaptive sliding mode control for unmanned underwater vehicles.
Unmanned Underwater Vehicles (UUVs) are disturbed by the environmental conditions, particularly from underwater currents. Likewise, mathematical model inaccuracies and unknown dynamics create an uncertain system. Hence, robust control approaches able to counteract such perturbations are relevant.
Related Publications
2022
- Adaptive Integral Terminal Sliding Mode Guidance and Control for a UUV Under PerturbationsIn 2022 Congreso Nacional de Control Automático, 2022